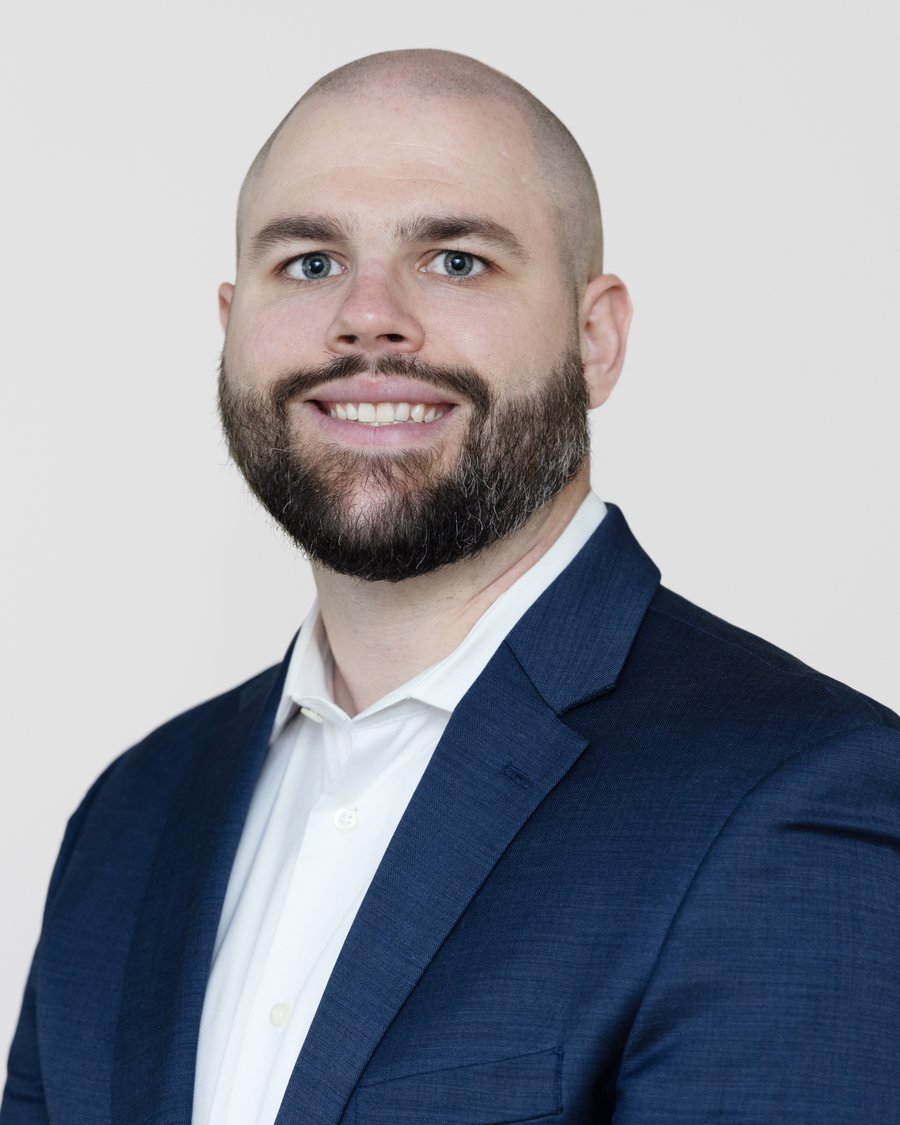
Portrait of Cameron Lerch
● Open to work · New York City

About me

I'm a multidisciplinary robotics engineer and researcher. My background spans autonomous systems, controls, simulation, mechanical engineering, physics, and mathematics. At Yale I earned an M.S. and M.Phil. in Mechanical Engineering as an NSF Graduate Research Fellow and advanced to Ph.D. candidacy in Prof. Ian Abraham's lab. There I developed algorithms that let teams of drones explore cluttered, unknown environments safely, combining ergodic trajectory optimization with control barrier functions, and tested them on real quadrotor swarms.

Before robotics, I spent years simulating materials and quantum phase transitions on HPC clusters, first at Missouri S&T, where I earned a B.S. in Physics summa cum laude, and then in Prof. Corey O'Hern's group at Yale. More recently, I worked where software meets hardware at Oxylus Energy, building a PyQt5 control system for multi-station lab hardware and designing a ventilated enclosure for a large-scale electrolysis stack.

I like taking an idea from theory to a working machine: researching it, developing the algorithm, writing the code, designing and prototyping the parts, and testing the physical system. Teaching matters to me just as much. I've spent years tutoring physics, mentoring students, and presenting technical work. I'm currently open to work and expanding my hands-on robotics toolkit with Viam's platform and hardware.

Education

Yale University

M.S. & M.Phil., Mechanical Engineering

2019 – 2025

View coursework →

Missouri S&T

B.S. Physics, Summa Cum Laude

2014 – 2019

View coursework →

Lee's Summit West

High School Diploma

2010 – 2014

View details →

Summit Technology Academy

PLTW Engineering

2012 – 2014

View details →

Experience

Oxylus Energy: Software and Mechanical Engineering Consultant
CoCuRo Lab (formerly Intelligent Autonomy Lab): Graduate Researcher, Multi-Robot Autonomy
O'Hern Research Group: Graduate Researcher, Computational Materials Science
Yale Teaching Fellow
Yale GECO: TGIF and Project Manager
Yale Summer Undergraduate Research Fellow 2018
The Leadership Alliance: member since 2018, National Symposium presenter
Missouri S&T Undergraduate Research
Missouri S&T Peer Learning Assistant, Engineering Physics Tutor
Early engineering work: CAD, prototyping, and fabrication
STEM Outreach and Mentoring: Funbotics, Yale Pathways, FIRST
NSF Graduate Research Fellowship 2019
Fuller Poster Competition winner
Missouri Undergraduate Research Day at the Capitol 2019
Sigma Pi Sigma and Society of Physics Students
S&T Astronomical Research Society, Vice President
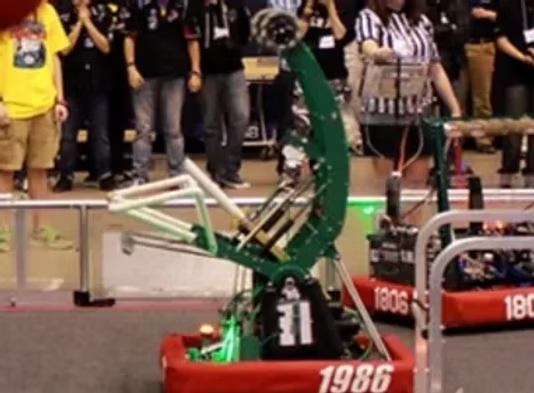
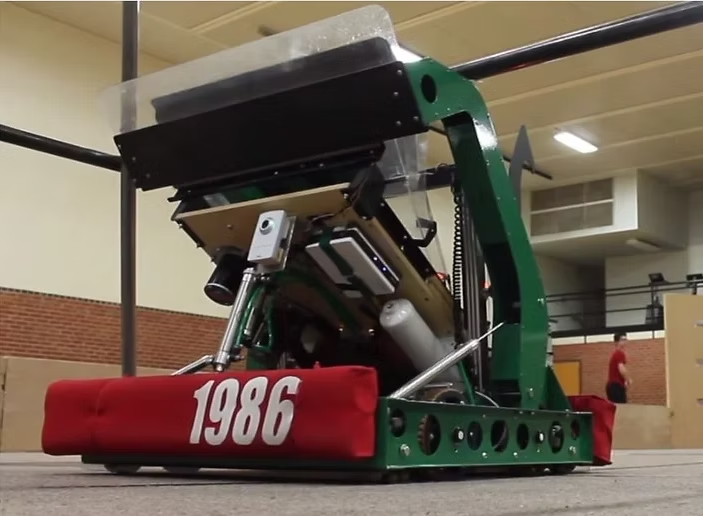
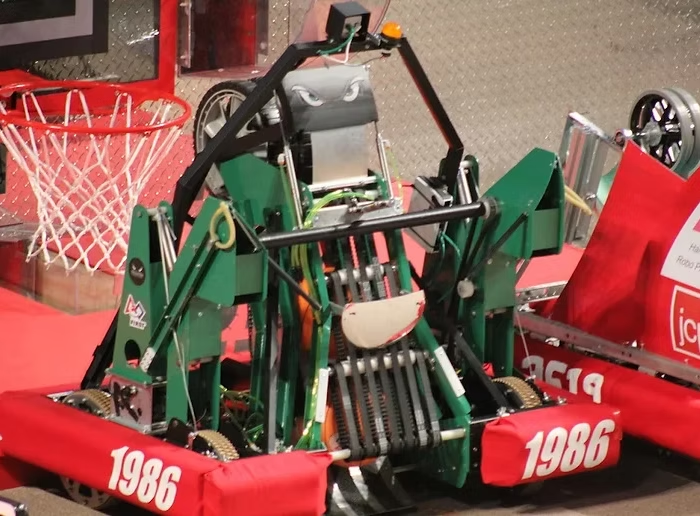
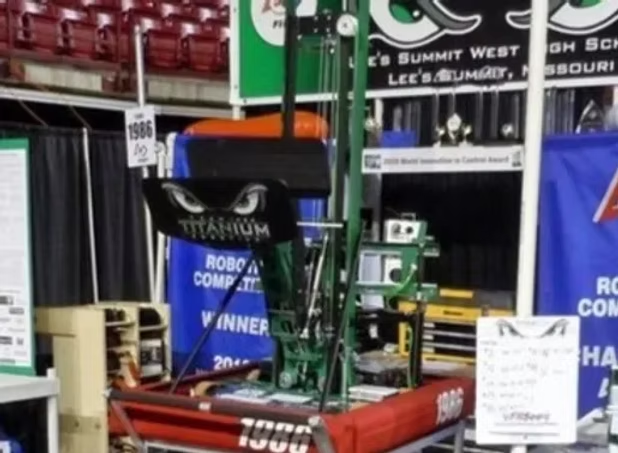
FIRST Robotics: Driver and Team Captain, Team 1986 Team Titanium
FIRST Dean's List Finalist 2014
National Honor Society, Lee's Summit West

Demonstrations

Research · ICRA 2023

Safety-Critical Ergodic Exploration

Collision-free search trajectories for single drones and drone teams in cluttered environments. Discrete control barrier functions are built into ergodic trajectory optimization, so the robots cover a space thoroughly while staying provably safe. Validated in simulation and on real quadrotors.

Personal project · Viam

ViamGreeter

An autonomous trade-show booth greeter built on Viam. A fixed webcam and a pre-trained person detector track passersby, and an SO-101 robotic arm turns toward each one, points, beckons, and waves. Runs on both a simulated and a real arm.

Personal project · Viam

Gripper Touch-Off

A Viam module that finds where a gripper's fingertips really are by touching them to the table, the way machinists set up a tool, then corrects the gripper's frame in the machine config so motion planning stops driving fingertips into the table.

Personal project · Viam

ViamObjectReconstruction

[One or two sentences on what this project does.]

Research · ICRA 2024

Energy-Aware Ergodic Search

Continuous exploration for battery-powered multi-agent teams. A battery model predicts each robot's state of charge, and planning trades battery use against coverage so at least one agent is always exploring.

Research · RSS 2024

Stein Variational Ergodic Search

Uses Stein variational inference to generate a diverse set of ergodic search trajectories at once, so a planner can choose among many good exploration strategies instead of committing to a single local optimum.

Work · Oxylus Energy

Multi-Station Instrument Control System

A modular PyQt5 application for running many lab stations at once: per-station configuration, dynamic USB device mapping, live sensor polling and telemetry, and validated, synchronized test schedules.

Work · Oxylus Energy

Electrolysis Stack Enclosure

A sealed enclosure for a large-scale electrolysis stack with fume-hood exhaust, designed using OSHA industrial ventilation guidance to dilute and remove carbon monoxide.

Research · Computational physics

Molecular Dynamics of Glasses & Soft Particles

LAMMPS simulations of bulk metallic glasses (glass-forming ability and rearrangements under cyclic shear) and of deformable particles clogging in hopper flows, run as parallelized workflows on HPC clusters.

Publications

Presentations & Posters

Robotics started for me in high school with FRC Team 1986, Team Titanium, in Lee's Summit, Missouri. I spent four seasons on the team from 2010 to 2014. For the first two I was on the mechanical subteam, designing and fabricating our competition robots. For the last two I was team captain and the robot's driver. Over those four seasons our robots won seven regional championships, and in 2013 Kraken reached the Newton Division finals at the FIRST Championship. I also volunteered more than 1,000 hours mentoring younger students through FIRST programs and summer camps.

Tutoring

I'm taking on tutoring students in New York City. I tutored engineering physics for three years as a Peer Learning Assistant at Missouri S&T and was a Teaching Fellow for dynamics at Yale. I enjoy helping students build real intuition for technical subjects, not just get through the next problem set.

Physics

High school, AP, and introductory college physics, from mechanics through electricity & magnetism.

Mathematics

Algebra through calculus, differential equations, and linear algebra.

Programming

Python and MATLAB for beginners, students, and scientists getting started with computation.

Robotics & Engineering

Intro robotics, CAD, and mentoring for FIRST and other student robotics teams.

  Get in touch about tutoring

GET IN TOUCH