Overview
After switching to Prof. Ian Abraham's lab, I researched robot control and trajectory planning for safe autonomous search and exploration. In late 2022 I passed my qualifying exam, presented my thesis prospectus to my committee, and was admitted to Ph.D. candidacy.
- Developed novel control algorithms for autonomous search and exploration with multi-robot systems.
- Used optimization-based trajectory planning for multi-robot teams.
- Engineered safety-critical control frameworks using control barrier functions for safe search and exploration in cluttered environments.
- Ran real-world and simulated experiments with teams of drones.
Projects
ICRA 2023 · First author
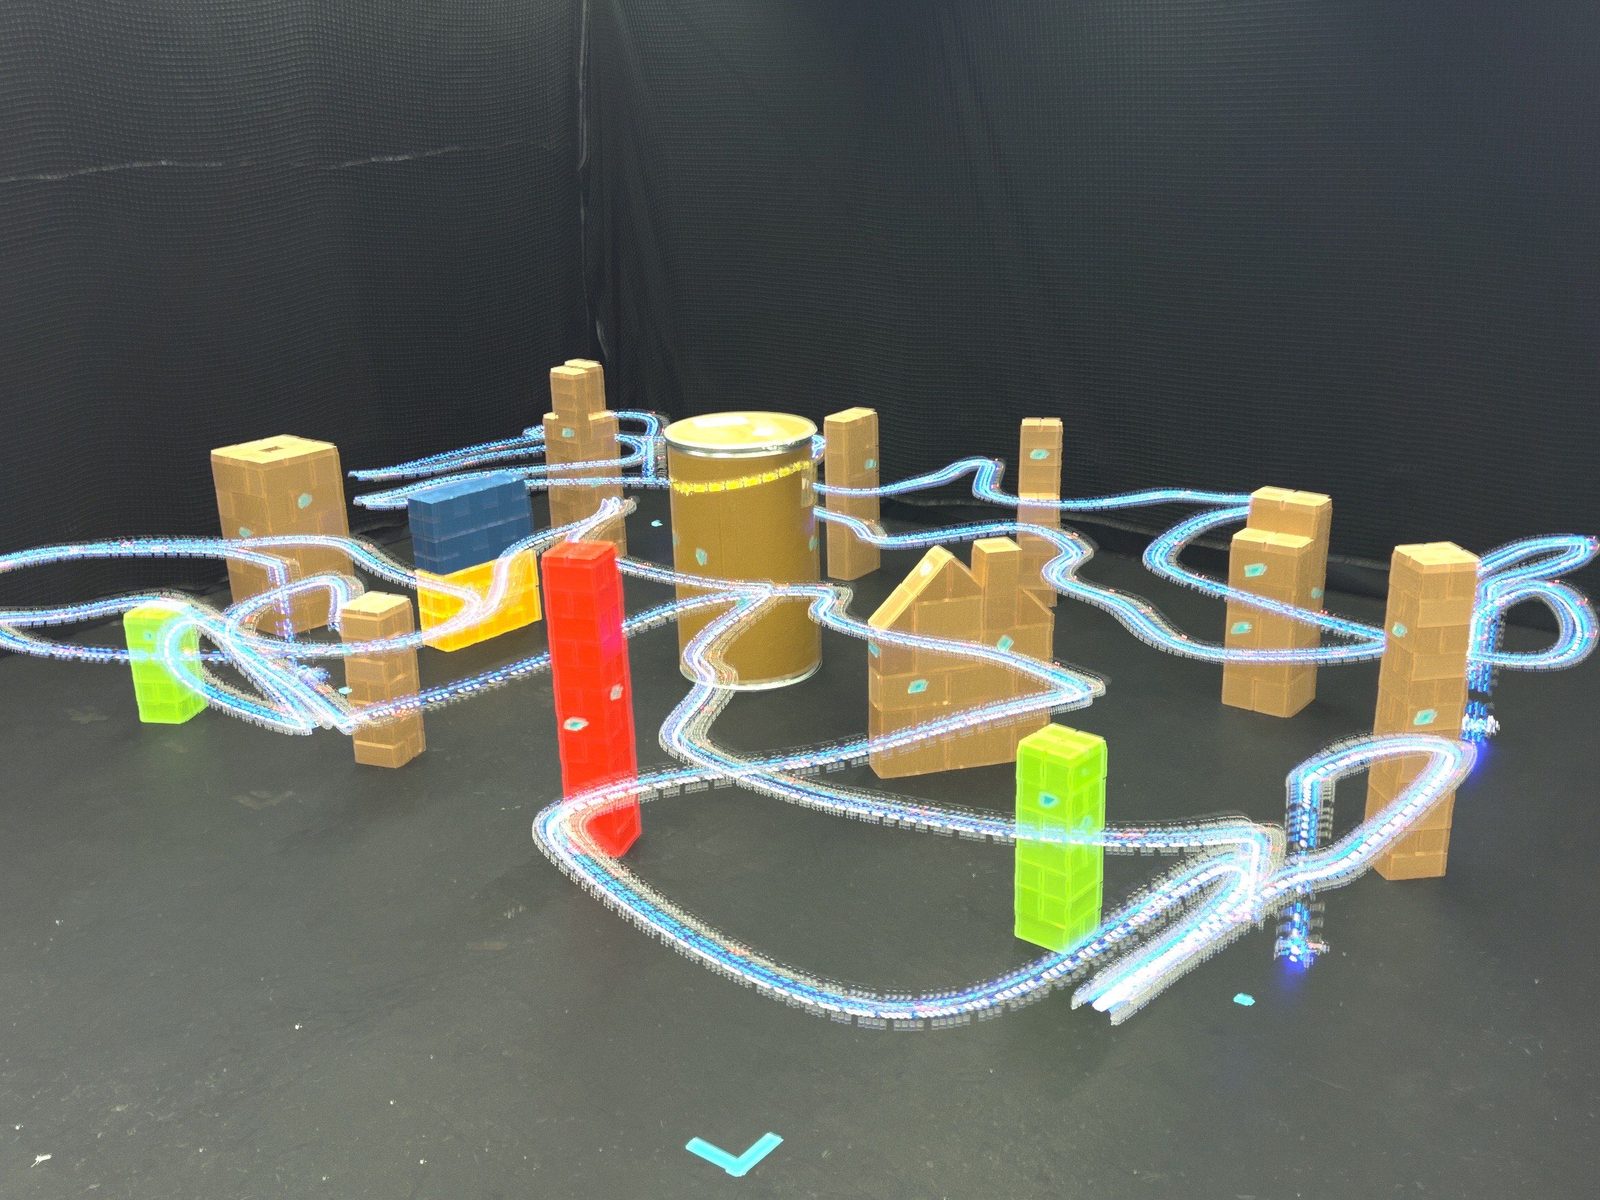
Safety-Critical Ergodic Exploration
Provably collision-free search trajectories in cluttered environments.
Details
ICRA 2024
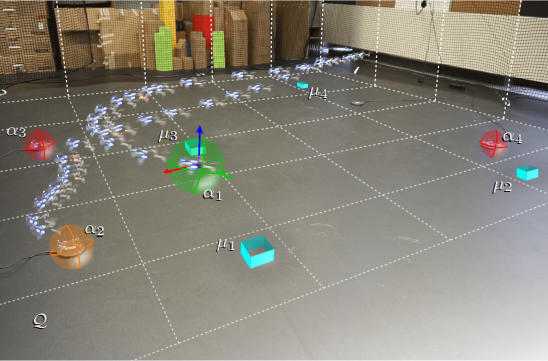
Energy-Aware Ergodic Search
Continuous exploration for battery-powered drone teams.
Details
RSS 2024
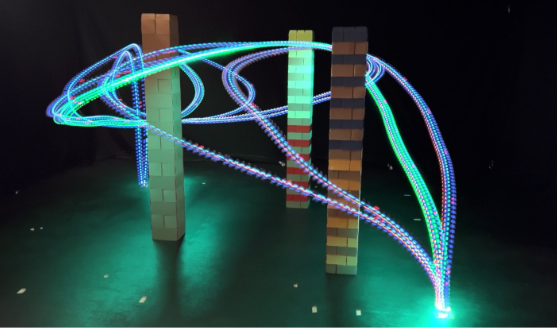
Stein Variational Ergodic Search
Diverse sets of search trajectories from variational inference.
Details
Lab demo
Yale "Y" Drone Swarm
A Crazyflie swarm that spells a "Y", built in one weekend.
Details
Teaching
While in the lab I also helped with Prof. Abraham's introduction to controls course, mentoring undergraduates on their robotics projects. More on teaching →
Gallery